Tong Xu

Tong Xu

PhD student for Robotics

George Mason University

RobotiXX Lab

Hello there!

I am currently a PhD candidate in the RobotiXX Lab at George Mason University, advised by Prof. Xuesu Xiao. I will also work with Prof. Hanbo Zhang and Jun Lv through a joint lab between the Shanghai Innovation Institute and Noematrix, focusing on robotic manipulation.

While pursuing my M.S. at the University of Southern California, I worked with Prof. Eshed Ohn-Bar at Boston University on visual odometry and motion estimation.

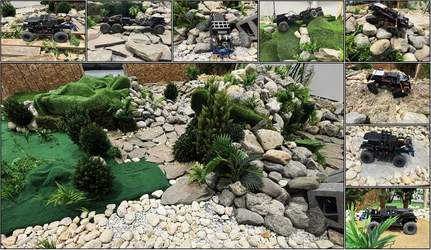
My research interests lie at the intersection of motion planning, robot learning, world models, and embodied intelligence. I am particularly interested in learning structured and transferable representations of physical interaction from large-scale robot data and leveraging them for prediction, planning, adaptation, and control across diverse embodiments and real-world environments.

Interests

  • Motion Planning
  • Robot Learning
  • World Models
  • Embodied Intelligence

Education

  • Ph.D. in Computer Science, 2023

    George Mason University

  • M.S. in Computer Science, 2021

    University of Southern California

  • B.E. in Network Engineering, 2017

    Nanjing University of Information Science & Technology
News

Publications

Preprint

Learning Scene-Aware Humanoid Locomotion through 3D Clutter from Immersive Human Demonstrations

NeSAM: Neuro-Symbolic Kinodynamics with Soil Adaptation for Off-Road Mobility

NeSAM: Neuro-Symbolic Kinodynamics with Soil Adaptation for Off-Road Mobility

VertiAKD: Adaptive Off-Road Kinodynamics on Vertically Challenging Terrain

VertiAKD: Adaptive Off-Road Kinodynamics on Vertically Challenging Terrain

Journal

Autonomous Ground Navigation in Highly Constrained Spaces: Lessons Learned from The Forth BARN Challenge at ICRA 2025

Autonomous Ground Navigation in Highly Constrained Spaces: Lessons Learned from The Forth BARN Challenge at ICRA 2025

CARoL: Context-aware Adaptation for Robot Learning

CARoL: Context-aware Adaptation for Robot Learning

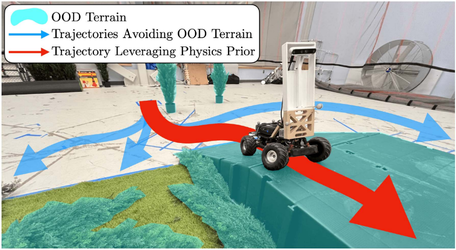
Pietra: Physics-informed evidential learning for traversing out-of-distribution terrain

Pietra: Physics-informed evidential learning for traversing out-of-distribution terrain

Conference

VertiAdaptor: Online Kinodynamics Adaptation for Vertically Challenging Terrain

VertiAdaptor: Online Kinodynamics Adaptation for Vertically Challenging Terrain

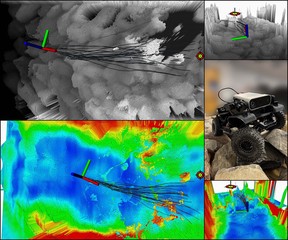
Traverse the Non-Traversable: Estimating Traversability for Wheeled Mobility on Vertically Challenging Terrain

Traverse the Non-Traversable: Estimating Traversability for Wheeled Mobility on Vertically Challenging Terrain

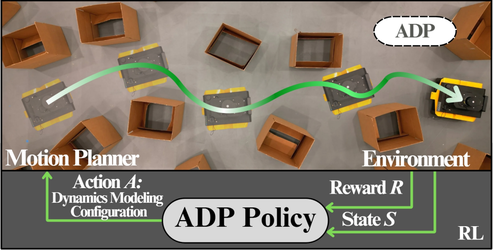
Adaptive Dynamics Planning for Robot Navigation

Adaptive Dynamics Planning for Robot Navigation

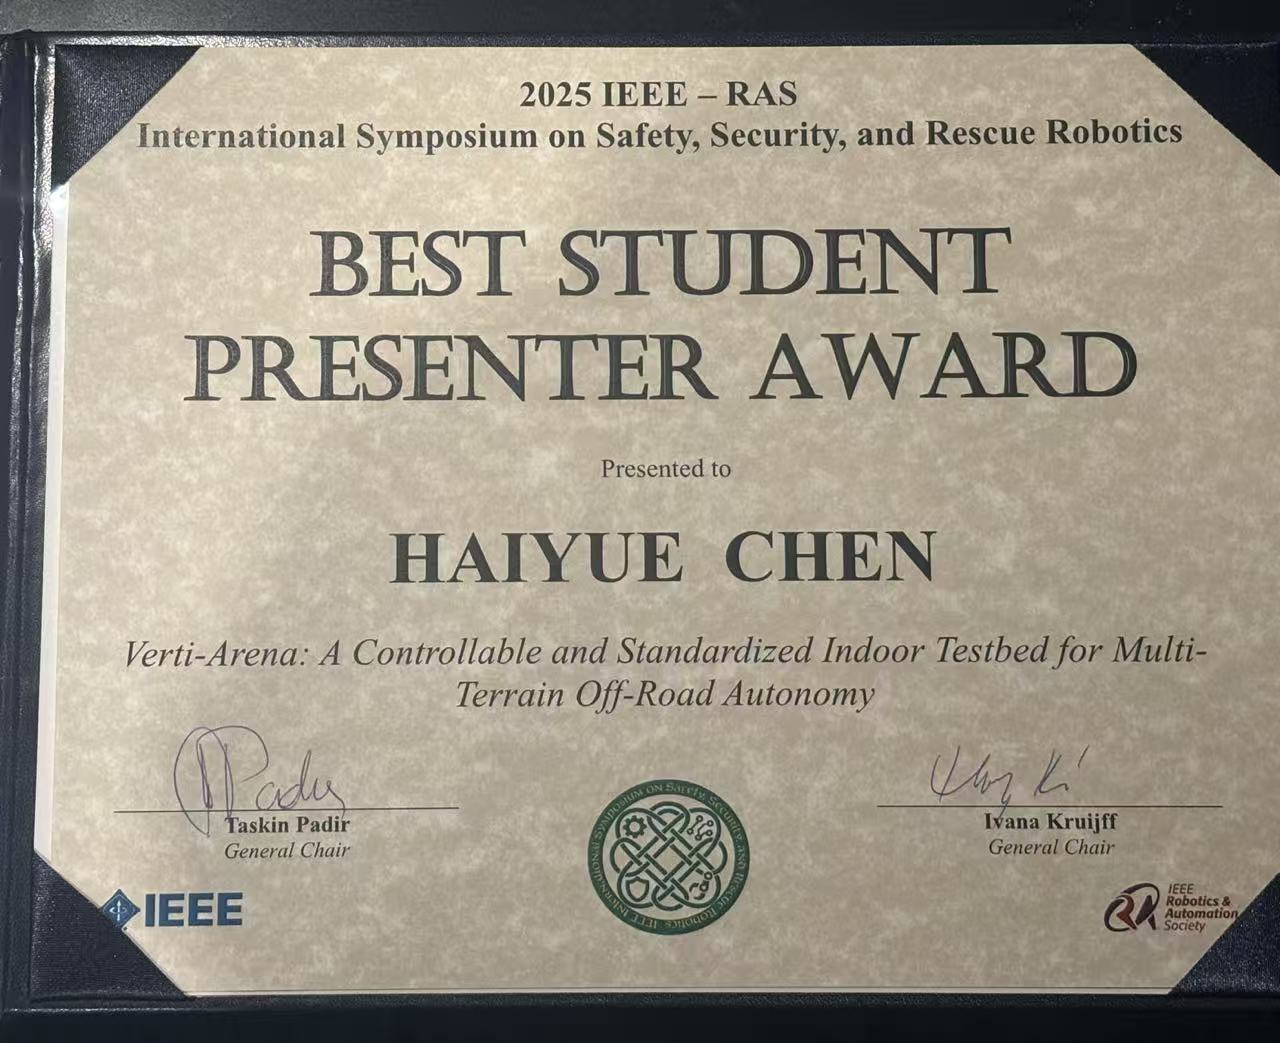
Verti-Arena: A Controllable and Standardized Indoor Testbed for Multi-Terrain Off-Road Autonomy

Verti-Arena: A Controllable and Standardized Indoor Testbed for Multi-Terrain Off-Road Autonomy

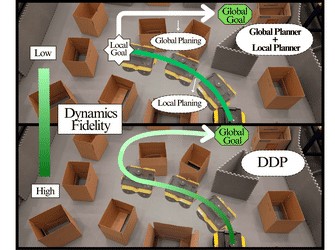
Decremental Dynamics Planning for Robot Navigation

Decremental Dynamics Planning for Robot Navigation

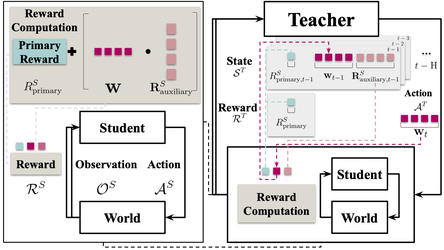
Reward Training Wheels: Adaptive Auxiliary Rewards for Robotics Reinforcement Learning

Reward Training Wheels: Adaptive Auxiliary Rewards for Robotics Reinforcement Learning

VertiSelector: Automatic Curriculum Learning for Wheeled Mobility on Vertically Challenging Terrain

VertiSelector: Automatic Curriculum Learning for Wheeled Mobility on Vertically Challenging Terrain

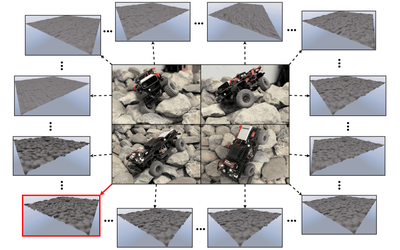
Verti-Bench: A General and Scalable Off-Road Mobility Benchmark for Vertically Challenging Terrain

Verti-Bench: A General and Scalable Off-Road Mobility Benchmark for Vertically Challenging Terrain

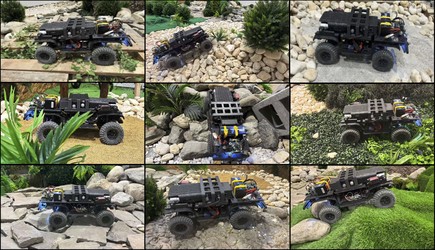
Reinforcement learning for wheeled mobility on vertically challenging terrain

Reinforcement learning for wheeled mobility on vertically challenging terrain

Experience


RobotiXX Logo

Graduate Research Assistant

RobotiXX

May 2024 – Present Fairfax
  • Research in off-road navigation, reinforcement learning, and foundation models
  • Leading the Verti-Bench for rapid kinodynamics adaptation cross different types of vehicles in off-road navigation scenario


George Mason University Logo

Graduate Teaching Assistant

George Mason University

Aug 2023 – May 2025 Fairfax
  • Designed student lab contents involving data structure, led weekly lab recitations and office hours
  • Created grading scripts and managed a team of 8 undergraduate teaching assistants


H2X Lab Logo

Research Intern

H2X Lab

May 2022 – Aug 2022 Boston
  • DeepVO - Visual Odometry with Deep Learning
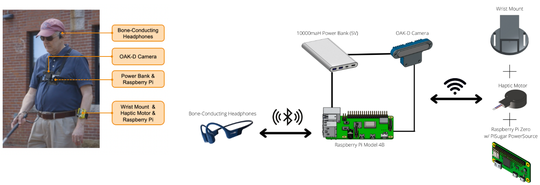
  • OpenGuide - A Scalable Human-Like Guidance System for Travelers with Visual Impairment

Projects

*

DeepVO

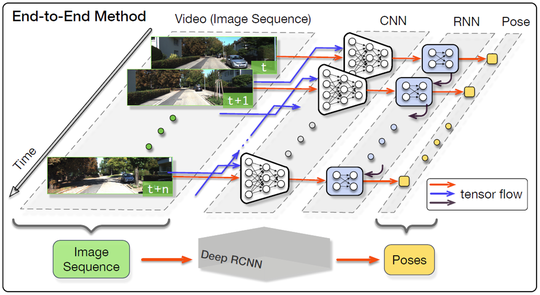
Reproduced Deep Visual Odometry architecture by integrating a pretrained FlowNetSimple model with LSTM. Achieved 14.8% performance improvement through epoch optimization and 8.4% improvement through hyperparameter tuning in the loss function, evaluated on KITTI and nuScenes datasets using translation and rotation RMSE metrics.

Cone Detection

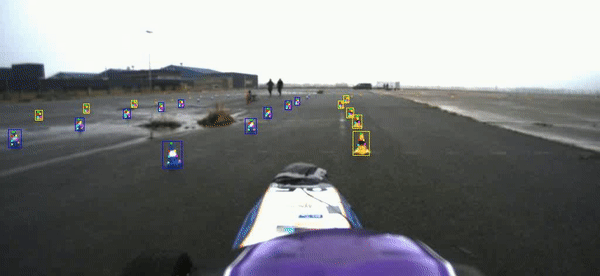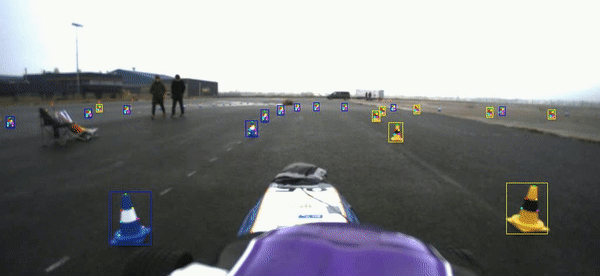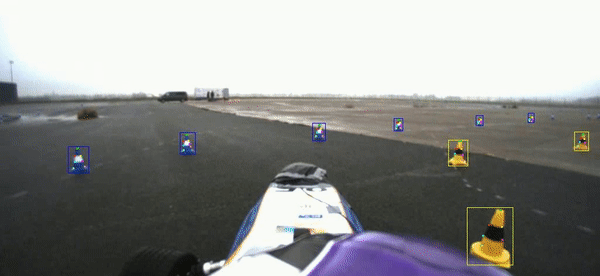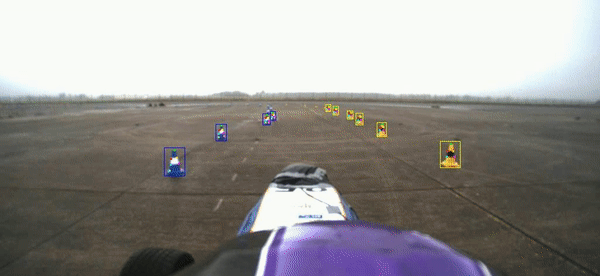
Implemented Faster R-CNN for cone detection by integrating Region Proposal Network with Fast R-CNN. Achieved 37.4% higher recall rate compared to YOLOv3 on a cone-annotated dataset, demonstrating superior detection performance.

OpenGuide

A Scalable Human-Like Guidance System for Travelers with Visual Impairment.

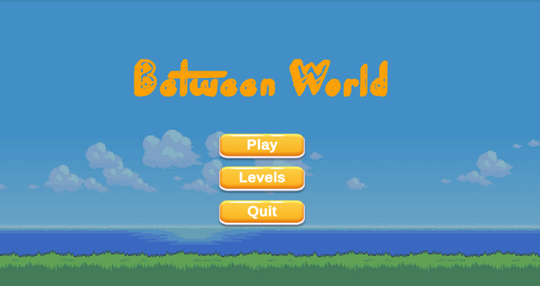
Between World

A 2D Unity platformer game where players switch between parallel worlds to solve traversal puzzles, avoid hazards, and progress through multi-stage levels.

Contact

  • txu25@gmu.edu
  • 4400 University Dr, Fairfax, VA 22030
  • RobotiXX Lab